- Robot type
- Robot AI and Software
- Location
- IrvineCaliforniaUSA
- Job type
- Product
- Posted
- Aug 27, 2026
Full-time
Humanoid Engineer, Manipulation
Job description
Field AI is transforming how robots interact with the real world. We are building risk-aware, reliable, and field-ready AI systems that address the most complex challenges in robotics, unlocking the full potential of embodied intelligence.
Job responsibilities
- Design, implement, and evaluate humanoid manipulation and loco-manipulation behaviors on real hardware
- Integrate perception, planning, control, grasping, whole-body coordination, and task execution into deployable robot workflows
- Run hardware experiments, analyze failures, and improve manipulation reliability across diverse objects, environments, and tasks
- Partner with system integration, hardware, field application, and testing teams to move capabilities from prototype to deployment
- Support teleoperation, data collection, and human-in-the-loop workflows for improving manipulation performance
- Build tools, metrics, and evaluation protocols for manipulation success, repeatability, failure recovery, and operator usability
- Debug cross-domain issues spanning software, sensors, actuators, end-effectors, calibration, timing, and field conditions
Job requirements
- MS or PhD in Robotics, Mechanical Engineering, Computer Science, or a related field preferred; BS considered with a demonstrated track record of hands-on robotics work across multiple physical systems — research projects, competition robotics, or internships with daily hardware exposure
- Hands-on experience with robotic manipulation, humanoids, mobile manipulation, dexterous hands, or contact-rich robotics — must include physical hardware; simulation-only backgrounds will not be considered
- Strong foundation in kinematics, dynamics, motion planning, control, and real robot experimentation
- Experience with C++, Python, ROS/ROS2, and Linux in a real robotics codebase
- Demonstrated ability to iterate quickly from experiment to working behavior on physical hardware; comfortable running daily hardware experiments, analyzing failures, and adapting approach in real-time
- Background appropriate for a junior-to-mid engineer; fresh MS and PhD graduates welcome
- Experience with humanoid platforms or contact-rich, dexterous manipulation systems — you’ve worked with robots that have hands, not just grippers
- Background in robot learning applied to physical hardware: imitation learning, reinforcement learning, or task and motion planning that you’ve validated on a real robot, not just in simulation
- You’ve taken a manipulation capability from prototype to reliable, repeatable field behavior — you know what it takes to close that gap and you’ve done it
- Track record of building evaluation frameworks for manipulation: test suites, metrics for success and failure, and the discipline to document and learn from what breaks
Similar jobs
Robot deals
All deals → Get deal
Deal · Everblog
10% off
 Shop
Shop · CircuitMess
DIY robot kits
Robot and gadget kits you build yourself.
 Shop
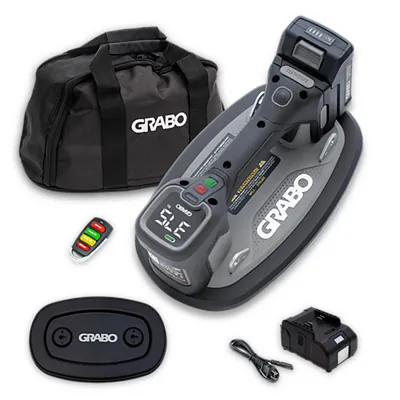
Shop · GRABO
Cordless vacuum lifter
GRABO Pro Brushless: the original cordless vacuum lifter for pavers, stone, glass and panels.
Like what we do? Buying through these links supports Bots n' Beans. We earn a commission at no extra cost to you. Thank you!