- Robot type
- Humanoid
- Location
- AustinTexasUSA
- Job type
- Business Operations
- Posted
- Oct 30, 2026
Senior / Staff Sim-to-Real Engineer (Tendon-based Robotic Hands)
Job description
We are looking for an experienced and autonomous Senior/Staff Sim-to-Real Engineer to bridge the gap between simulation and physical hardware for our advanced tendon-driven robotic hands.
Simulating tendon-driven mechanisms is notoriously difficult due to complex routing, friction, elasticity, and non-linear transmission dynamics. In this role, you will be responsible for creating elegant, highly accurate abstractions of these complex mechanisms for our simulators, and proving they work through rigorous empirical testing and system identification.
You will play a critical role in our control pipeline, ensuring that Reinforcement Learning (RL) policies trained in simulation successfully…
Job responsibilities
- Tendon Mechanism Abstraction: Develop and implement simple, computationally efficient, and highly accurate physical abstractions for complex tendon-driven mechanisms in simulation.
- System Identification & Validation: Design and execute empirical testing protocols to identify system parameters and prove that your simulation abstractions accurately reflect physical reality.
- Actuator Characterization: Perform rigorous system ID and control tuning on low friction robotic actuators to ensure high-fidelity torque and effort mapping.
- Rigid Multi-Body Calibration: Drive the kinematic calibration, inertial parameter identification, and effort production verification across our multi-body hand systems.
- Sim-to-Real Pipeline Ownership: Collaborate closely with the RL and Controls teams to ensure the dynamics engine and domain randomization strategies perfectly support zero-shot or few-shot transfer of control policies…
- Technical Leadership: Operate autonomously to identify bottlenecks in the sim-to-real pipeline, propose solutions, and lead the technical execution from concept to deployed hardware.
Job requirements
- Experience Level: 5+ years of industry or development experience post graduation in robotics, controls, or physical simulation, operating at a Senior or Staff level.
- Sim-to-Real Expertise: Proven track record of successfully transferring RL-based control policies from simulation to physical hardware.
- System ID & QDD Actuators: Deep, hands-on experience with control, system identification, and characterization of Quasi-Direct Drive (QDD) actuators.
- Dynamics & Calibration: Strong foundation in rigid multi-body dynamics, kinematic calibration, and inertial identification.
- Hardware Profiling: Proven experience verifying effort production, characterizing friction/backlash, and diagnosing hardware-software discrepancies in complex mechanisms.
- Autonomy: Demonstrated ability to take an open-ended problem (e.g., "our policies fail when the tendon stretches"), design an empirical test, update the simulation model, and resolve the reality gap independently.
- Specific experience modeling, calibrating, or controlling tendon-driven or cable-driven robotic systems.
- Familiarity with modern RL environments and physics simulators (e.g., MuJoCo, Isaac Sim/Gym, Drake, or Bullet).
Similar jobs
Apptronik · Business Operations
Senior Benefits Specialist
Austin, Texas
Apptronik · Business Operations
Talent Acquisition Recruiter (Contract)
Austin, Texas
Apptronik · Business Operations
Senior Compensation Business Partner
Austin, Texas
Apptronik · Business Operations
Staff People Technology Specialist
Austin, Texas
Robot deals
All deals → Get deal
Deal · Everblog
10% off
 Shop
Shop · CircuitMess
DIY robot kits
Robot and gadget kits you build yourself.
 Shop
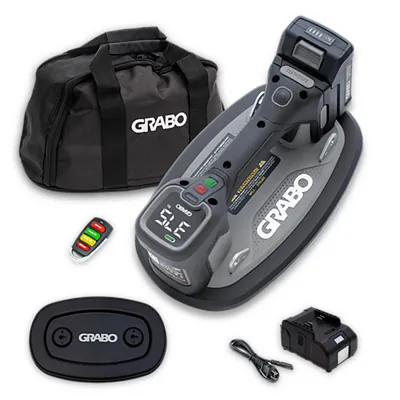
Shop · GRABO
Cordless vacuum lifter
GRABO Pro Brushless: the original cordless vacuum lifter for pavers, stone, glass and panels.
Like what we do? Buying through these links supports Bots n' Beans. We earn a commission at no extra cost to you. Thank you!